Rehabilitation Engineering and Electromechanical Design Lab
|
|
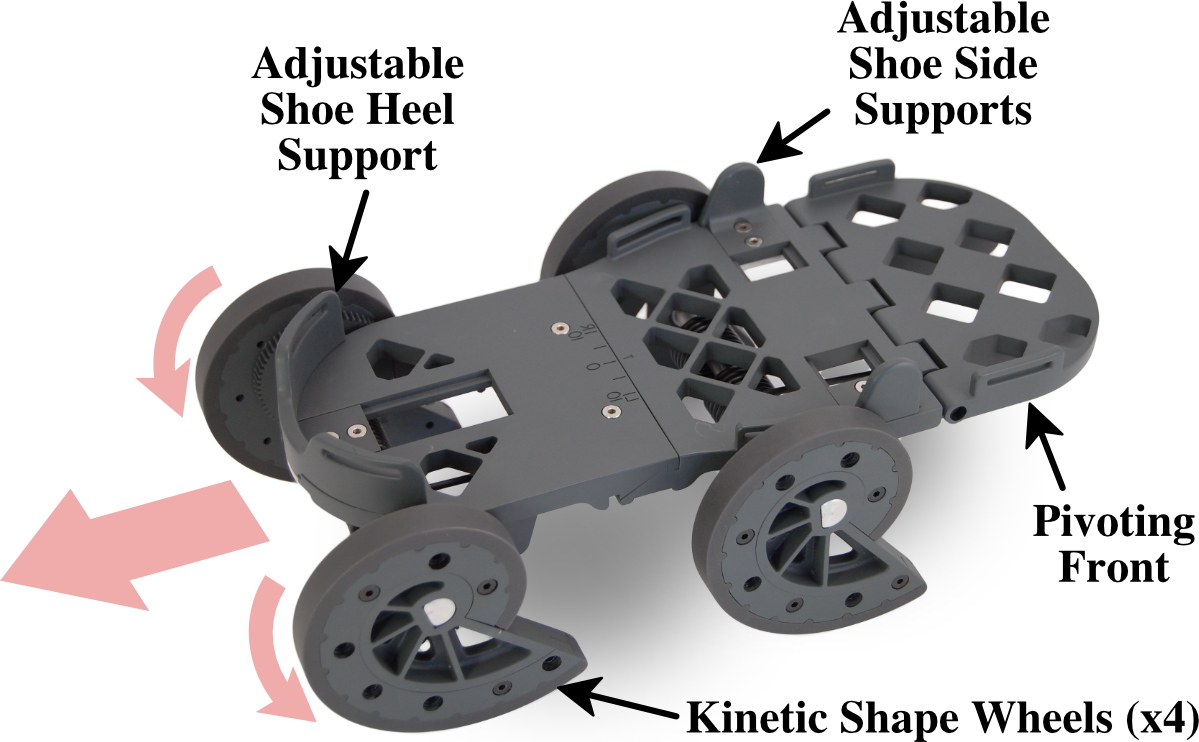
| Our research focuses on rehabilitation engineering, haptics, and human physical interaction, with an emphasis on understanding how people respond and adapt to changes in their movement. Much of this work examines asymmetric movement, including walking after stroke, and how mechanical or haptic interactions can be used to influence movement and motor adaptation. These studies range from fundamental models of asymmetric gait and human-human physical interaction to translational rehabilitation technologies such as evergait™ Go. | ||
Haptics and Rehabilitation Synergy In our lab, we explore the sense of touch through haptics, investigating thermal responses, coordinated motions, and force feedback interactions. Our work in haptics seamlessly integrates with our rehabilitation research, aiming to restore and enhance motor functions. By leveraging insights from both fields, we design interventions that can elicit specific responses, whether for rehabilitation purposes or enriching virtual environments. For instance, our bimanual research benefits both training scenarios (like those for pilots and surgeons) and rehabilitation, where the healthy limb can guide the impaired one. | ||
Advancing Home-Based Rehabilitation One of our primary goals is to enable effective rehabilitation outside of clinical settings, such as in patients' homes. Home-based rehabilitation is crucial for meeting the growing demand for physical therapy while reducing healthcare costs. We strive to understand how altering physical parameters can improve walking and reaching abilities, and how these changes can lead to lasting cognitive improvements that transfer to real-world tasks. | ||
Interdisciplinary Approach Our lab's work is inherently interdisciplinary, drawing upon engineering, haptics, human-robot interaction, rehabilitation, and medical robotics. This multifaceted approach allows us to tackle complex rehabilitation challenges from multiple angles, ensuring comprehensive solutions that address both physical and cognitive aspects of recovery. | ||
Research Projects | ||
evergait™ Go — Overground Gait Rehabilitation After Stroke (click for more information):
The underlying technology has been evaluated in multiple published studies with people after stroke, including research examining gait symmetry, walking speed, balance, mobility, and the persistence of improvements after treatment. A major focus of our current research is translating this approach from the laboratory and rehabilitation clinic into a practical system that can support continued gait rehabilitation at home. This work includes wearable sensing to quantify walking asymmetry and enable therapists to review rehabilitation activity outside the clinic. The evergait Go research has been supported by the Eunice Kennedy Shriver National Institute of Child Health and Human Development (NIH NICHD, R21HD066200), the Florida High Tech Corridor, and the University of South Florida. The technology is protected by U.S. and European patents and has been licensed by USF to evergait LLC, a USF spinout developing the research into the evergait™ Go rehabilitation system. Learn more about the research, publications, and development of evergait Go. | ||
|
Choose Your Own Lecture (CYOL) — Interactive and Self-Paced Learning (click for more information): Online and asynchronous learning gives students flexibility to learn at their own pace, but prerecorded video lectures often lose the interaction and immediate feedback available in a classroom. Our engineering education research investigates how self-paced video learning can be combined with instructor interaction to provide students with support at the moment they need it. This work led to Choose Your Own Lecture (CYOL), an interactive learning platform that allows students to pause, rewind, or accelerate prerecorded lectures while asking questions at the exact point in a video where they arise. Student questions are linked to specific moments in the lecture and can receive live or delayed responses from an instructor or teaching assistant. These responses become reusable, time-anchored learning resources that future students can access when they encounter the same material. CYOL has been evaluated across multiple courses and institutions, with research examining self-paced learning, student engagement, instructor feedback, and the use of interactive video in online, hybrid, and flipped classrooms. This research has been supported by the National Science Foundation (NSF Award #2315353). Learn more about CYOL, published research, and the interactive learning platform. | ||
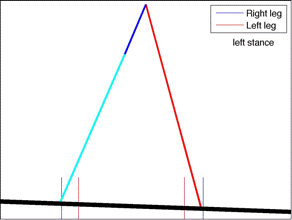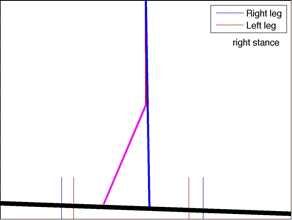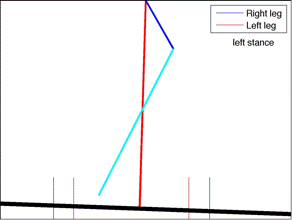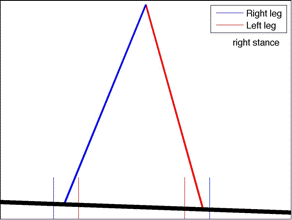
Passive dynamic walkers (PDWs) are mechanical models that can walk down a slope using gravity as their only energy source, without motors or active feedback. We use these models to study the mechanics of asymmetric gait and how changes to physical parameters can alter walking patterns. By changing a parameter on only one leg, such as knee position, the walker can produce stable gait patterns in which the two legs have consistently different step lengths. This fundamental work helps us understand how mechanical changes influence gait symmetry and how the walking system responds to an imposed asymmetry. Those questions are directly relevant to gait rehabilitation after stroke, where rehabilitation approaches such as evergait™ Go intentionally alter the mechanics experienced by the two legs to promote gait adaptation and more symmetric overground walking. | ||
Bimanual Motions:
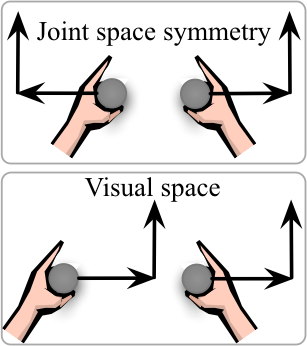
To investigate potential approaches for robot-assisted stroke rehabilitation, we have performed haptic tracking experiments in which individuals experience a trajectory with one hand and attempt to recreate it with the other. The results help us understand how physical coupling, spatial reference frames, and bilateral coordination influence motor performance. More broadly, this work complements our gait rehabilitation research by examining how interactions between the two sides of the body can be used to understand and potentially improve movement after neurological injury. If you would like to test your coordination on a bimanual game, check out Pat & Rub, an app we developed to demonstrate coordinated bimanual movements and explore which combinations of movement are easiest and most difficult to perform. | ||
Human-Robot-Human Interaction (click for more information):
Many important tasks involve two people physically interacting with one another. People may carry an object together, an instructor may physically guide a student learning a movement, or a physical therapist may guide a patient during rehabilitation. These interactions motivated our research into human-human physical cooperation: before a robot or rehabilitation device can effectively assist a person’s movement, we need to understand how humans physically assist and respond to one another. Our Human-Robot-Human Interaction research measures the forces and movements of two people jointly performing a task and compares those interactions with human-robot interaction. We have found that cooperating partners can improve task performance, temporally specialize their contributions, and interact in ways that differ from a person working with a robot. Understanding these principles helps inform the design of rehabilitation robotics, haptic systems, and physical human-robot interaction in which technology must influence movement while still allowing the person to actively participate. | ||
| Haptics (EML 4593/6930): Part of the Haptics class project is to build a haptic device and/or conduct psychophysical experiments. Here are a few photos of the demonstrations from Spring 2010, Spring 2011, Spring 2012, Spring 2013, Spring 2014, and Fall 2015. |